## How I Can Help.
Solution Design Consulting
End-to-end architecture for robotics & AI systems — from concept and feasibility to MVP and field deployment.
Robotics Consulting
Autonomous platforms, ROS stacks, motion planning, navigation and embedded controllers for outdoor/field robots.
AI Consulting
Deep learning, reinforcement learning and decision systems tailored to real-world, data-scarce environments.
Computer Vision
Perception pipelines, semantic segmentation, SLAM and visual servoing for robotic and industrial applications.
Hardware Startup Advisory
PCB & embedded design reviews, prototyping strategy, research-to-product transfer, and grant scoping.
Software Startup Advisory
Technical co-founder support: stack choices, MVP scoping, hiring and engineering culture for early-stage teams.
Talks for Events
Keynotes, panels and workshops on agri-robotics, AI in agriculture, and bringing research robots to market.
## The Robotics Operator.
Dr.-Ing. Alireza Ahmadi is the Founder and CEO of DynamoBot GmbH (Dynamic Mobile Robotics) — active in the agricultural robotics and AI branch — with over 15 years of experience across robotics R&D, embedded systems and precision agriculture.
He holds a B.Sc. in Electronics & Embedded Circuits Engineering from Tabriz Technical College (2013), an M.Sc. in Geodetic Engineering & Mobile Sensing from the IPB, University of Bonn (2019), and a Ph.D. from the Agricultural Robotics & Engineering Institute at the University of Bonn (2025), where he developed BonnBot-I — the precise weed management platform that became the technological foundation of DynamoBot.
His work has been recognized internationally — including the IROS 2022 Best Paper Award on Agri-Robotics (sponsored by YANMAR, Kyoto), the Transfer Prize 2025 from Uni-Bonn, the Bayer Golden Ticket II for crop science startups, a Silver Medal at WorldSkills 2013 in Leipzig, and multiple podium finishes at RoboCup. He also serves as a reviewer for IEEE RA-L, JFR, ICRA, IROS, and Computers & Electronics in Agriculture (Elsevier).
## Career Log.
- Jan 2023 → now--founder
Founder & CEO
DynamoBot GmbHBonn, DEFounded DynamoBot (Dynamic Mobile Robotics). Building a family of autonomous robots for agriculture and AI-driven precision weeding.
- 2020 – 2025--research
Ph.D. Candidate & Research Assistant
Agricultural Robotics & Engineering Institute, University of BonnBonn, DEWith Prof. Chris McCool: precise weed management, vision & action, DL-based machine vision, autonomous vision-based outdoor navigation, and RL-based multi-agent intervention planning.
- Apr – May 2023--industry
R&D Engineer (Part-time)
Farming Revolution GmbHGermanyNavigation in arable farms.
- 2019 – 2023--industry
R&D Engineer (Part-time)
Escarda Technologies GmbHGermanyDesign & implementation of the Escarda laser-weeding platform: weeding action planner, robotics system design & simulation, embedded controller design and ROS integration.
- 2017 – 2018--research
Research Assistant
Photogrammetry & Robotics Lab (IPB), University of BonnBonn, DEWith Prof. Cyrill Stachniss: visual-servoing-based navigation, RGB-D volumetric mapping & SLAM, prototype AgriBot platform, and a portable RedEdge-compatible labeler gun for ag datasets.
- 2017--research
Research Assistant (Part-time)
CAST Lab, University of TehranTehran, IRMember of the Surena 4 humanoid simulation team — motion and walk generation for biped humanoids.
- 2012 – 2017--industry
R&D Engineer (Part-time)
PishRobotTehran, IREmbedded circuit & PCB design, C++/C# interfaces, instructor for humanoid robots & ROS, and extending MBlock (Java) for the company's product line.
- 2013 – 2016--research
Research Assistant (Part-time)
Polytechnique University of Tehran (AUT)Tehran, IRHumanoid and @Home service-robot teams: embedded controllers, walk & action generation for biped robots, UGV motion control, and educational robotic platforms.
- 2013 – 2015--teaching
Lab Instructor — National Skills Competition Organizer
Technical & Vocational Organization of IranIranInstructor for mobile robotics, embedded controllers (AVR/ARM) and programming (Python, C++); organizer of the national mobile-robotics skills competition.
## Education.
Ph.D., Precision Weed Management — Robotics & Robotic Vision
M.Sc., Geodetic Engineering & Mobile Sensing
B.Sc., Electronics & Embedded Circuits Engineering
## Projects.
DynamoBot
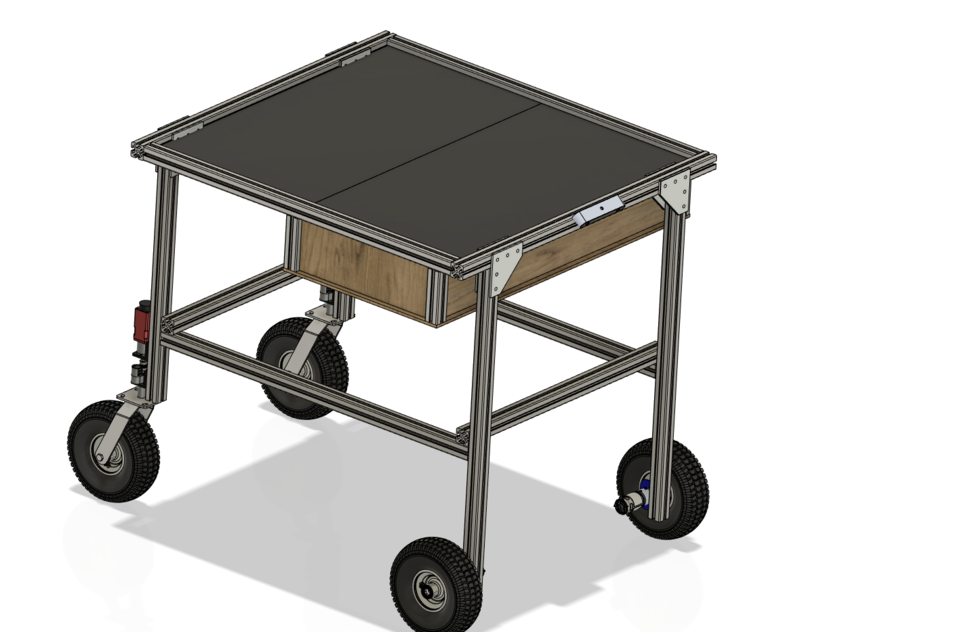
Bio-Diversity-Aware Weeding Trailer.
PhenoRob — BonnBot
Precision weed management robot.
Escarda
Intervention & perception head for laser-based weeding.
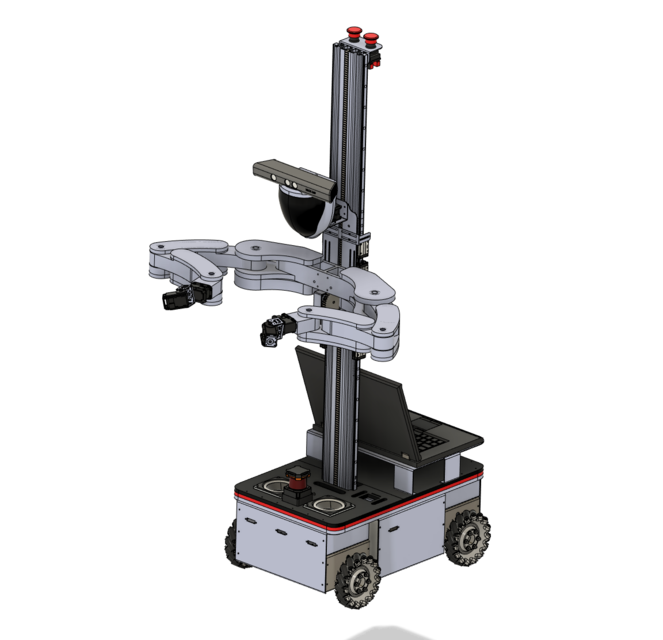
AgriBot · DynaMap
Deformable-objects volumetric mapping.
Surena 4
Humanoid simulation team.
Sepanda @Home
Domestic service robot platform.
AUTMan Humanoid
Teen-size humanoid for RoboCup.
## Recognition.
- [2025]Transfer Prize — University of Bonn, Germany.
- [2025]Bayer Golden Ticket II — crop science & ag-tech startups (Bayer × HTGF), Bonn.
- [2025]Ignition digiHub Pre-Seed Startup Grant — PTJ & Land NRW, Germany.
- [2024]Prototyping Grant (Rounds 1 & 2) — PhenoRob / DFG, for DynamoBot spin-off.
- [2023]Prototyping Grant — enaCom Transfer Center, University of Bonn (DynamoBot spin-off).
- [2022]IROS Best Paper Award on Agri-Robotics (sponsored by YANMAR) — Kyoto, Japan.
- [2015]Third Place — RoboCup, Humanoid Teen-size League. Hefei, China.
- [2015]Second Place — RoboCup Technical Challenge, Humanoid Teen-size. Hefei, China.
- [2014]Best Technologist — National Elites Foundation of Iran.
- [2013]Silver Medal (2nd place) — 42nd WorldSkills International, Mobile Robotics. Leipzig.
- [2013]Gold Medal — Best of the Nation, 42nd WorldSkills. Leipzig.
- [2012]First Place — 13th Iran TVTO National Skills Competition, Mobile Robotics. Karaj.
- [2012]Member — Iran National Elites Foundation.
## Service & Teaching.
Reviewer — IEEE Robotics & Automation Society
Reviewer for RA-L, Journal of Field Robotics (JFR), Computers & Electronics in Agriculture (Elsevier), ICRA, and IROS.
Teaching — University of Bonn
- › MSR-Project — Mobile Sensing & Robotics (autonomous navigation, farm monitoring & planning)
- › B.Sc. final-project supervisor — mechanical weeding tools for mobile robots
## Selected Publications.
## GitHub Activity.
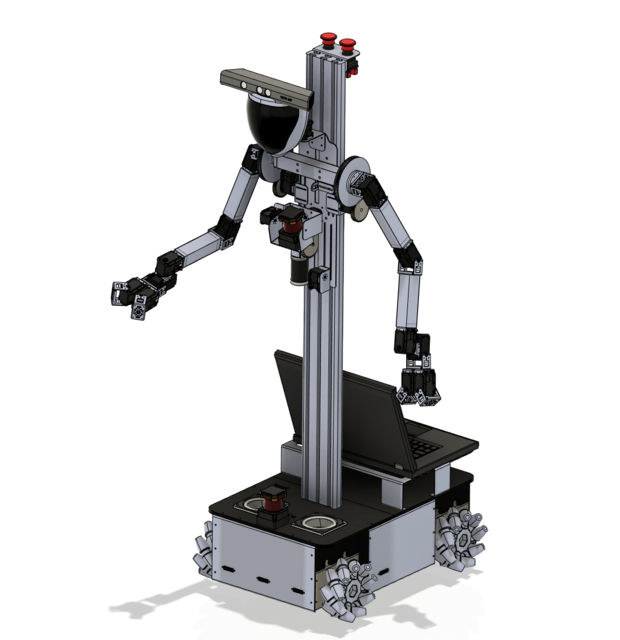
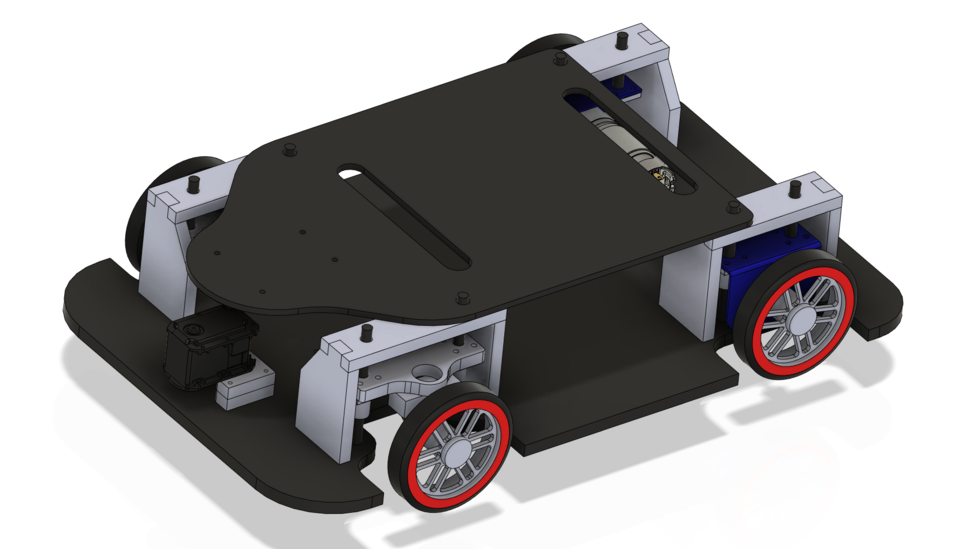
## CAD & Mechanical Design.
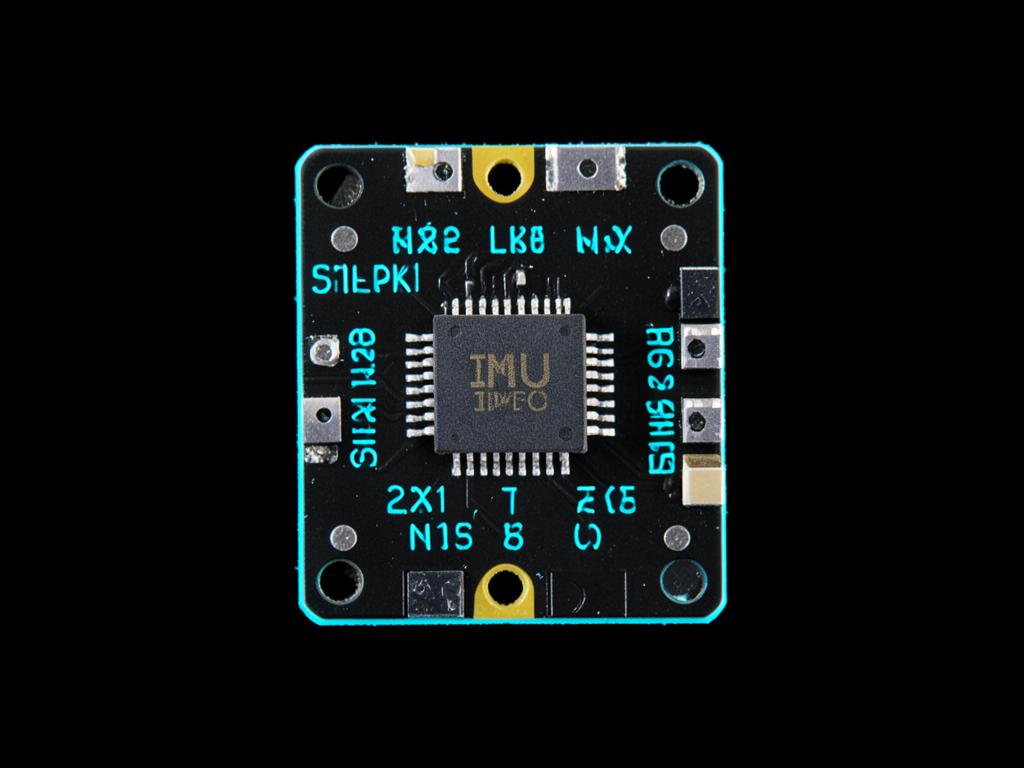
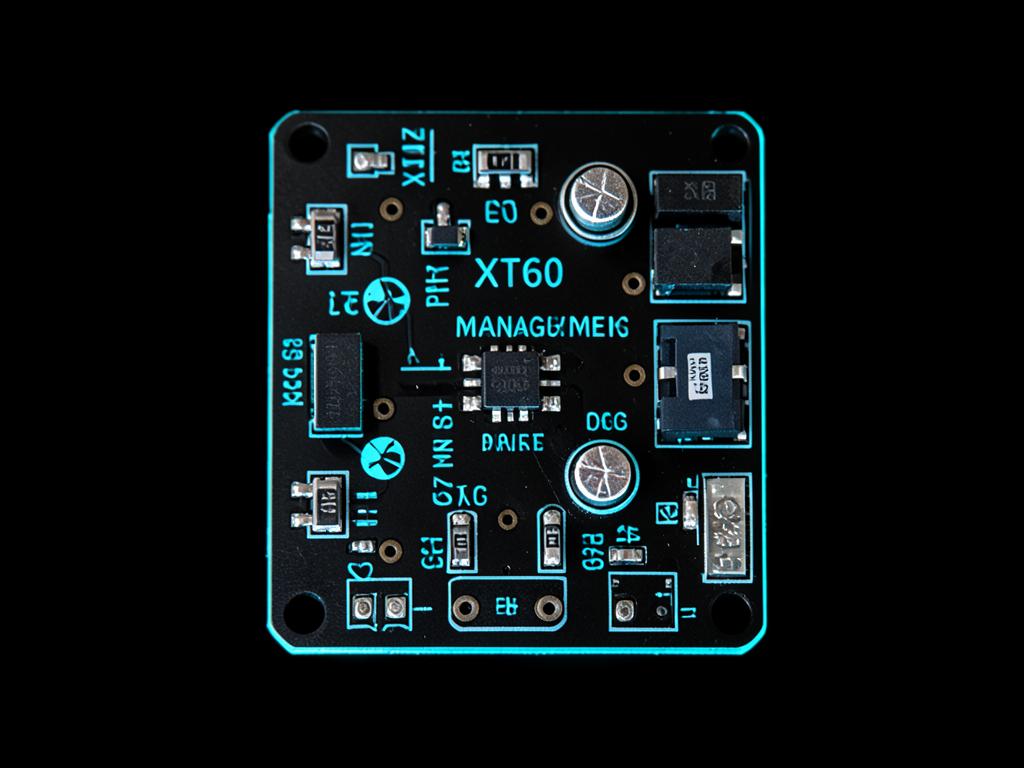
## Electronics & PCB Design.
## Practical Robotics — Videos.



## Let's Talk Robots.
{
  "address":   "Nussallee 5, 53115 Bonn, DE",
  "linkedin":  "linkedin.com/in/alirezaelecat",
  "github":    "github.com/alirezaahmadi",
  "youtube":   "@DynamoBotGMBH",
  "company":   "dynamobot.de",
  "languages": "Persian · Azeri · English · Deutsch (B2)"
}